I attended the IEEE International Conference on Intelligent Robots and Systems (IROS) 2024, held in Abu Dhabi from October 14 to 18, 2024.
This was my first time attending an international conference in person since the COVID-19 pandemic, and I was genuinely excited even before the trip.
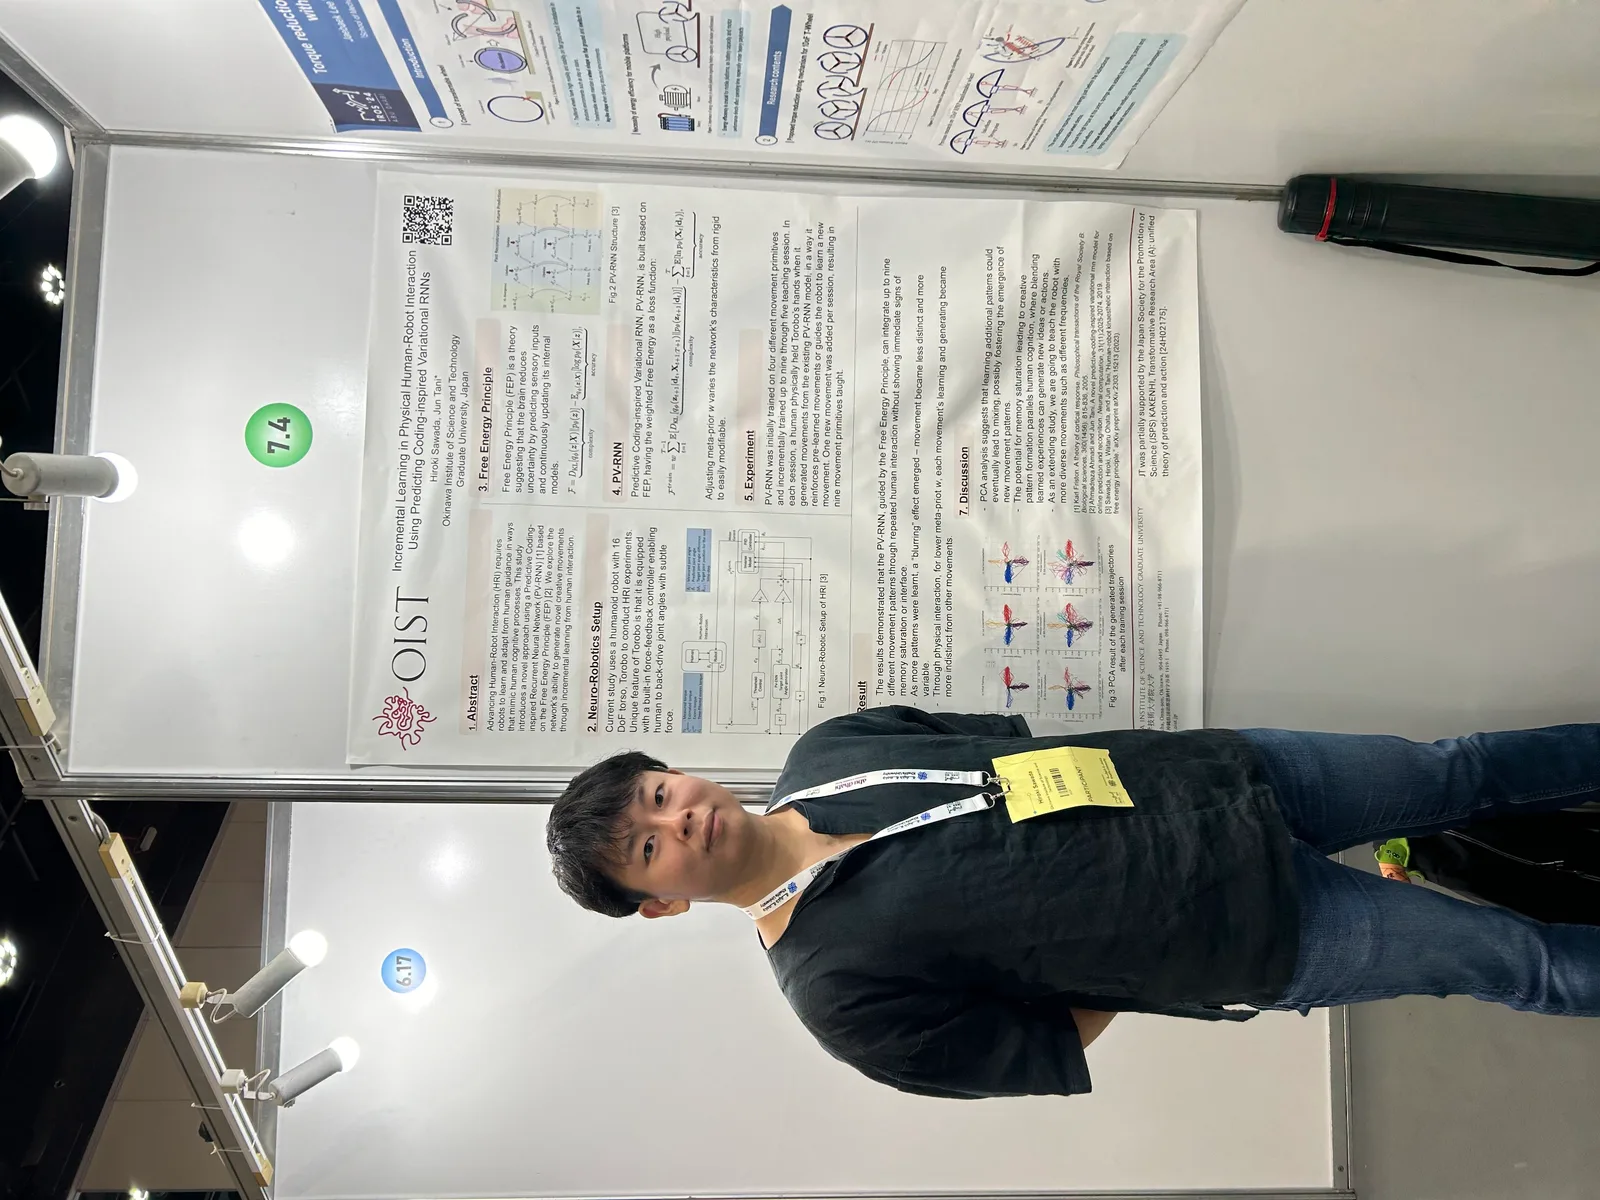
In my presentation, I extended previous research on the Predictive-Coding inspired Variational RNN (PV-RNN). Specifically, I analyzed how the internal state representations change when a robot incrementally learns new motions, using principal component analysis (PCA) to capture these changes.
Since PV-RNN learns each motion in a nonlinear manner, I hypothesized that incremental learning might lead to emergent novel behaviors. To test this, I incrementally increased the number of learned motions from four to nine by guiding a humanoid robot’s two arms. The results showed that the internal representations of different motions gradually began to blend together, as indicated by the expanding distributions observed in PCA space.
Unfortunately, even with nine motions, no creative or entirely novel behaviors emerged. I am currently considering how to further develop this line of research, but for now, I will put this study on hold as I am heading to France for an internship. Below are the poster presented at IROS and my participation certificate.
発表ポスターはこちら
参加証はこちら